// Work_Log
// Work_Experience
HMI Project Intern
Schneider Electric India, Bengaluru
Engineered a Dark Theme UI for Industrial HMI Software
Took ownership of a full interface overhaul for Schneider Electric's EcoStruxure Operator Terminal Expert (EOTE) software, moving from a high-contrast default theme to a polished dark UI designed for operators working long shifts in demanding industrial environments.
- 01. UI Engineering: Built the dark theme interface using C# and WPF, handling styling, component theming, and visual hierarchy to ensure readability and consistency across all operator-facing screens.
- 02. Operator Experience: Focused the design around reducing visual fatigue — a critical factor for control room operators monitoring systems over extended periods in low-light industrial settings.
- 03. Development Lifecycle: Contributed to the HMI group's broader development pipeline, documenting software licensing enhancements and supporting feature integration across product releases.
Project Intern
Bahrain Electromechanical Services Company (BEMCO), Bahrain
Contributed to a $525M Infrastructure Project
Worked on live electrical design and systems integration for the Bahrain Marina Development — a large-scale infrastructure project requiring precision engineering across grounding, protection, and building safety systems.
- 01. Grounding & Protection Systems: Designed and optimized grounding systems achieving sub-1-ohm resistance, and implemented lightning protection schemes to safeguard the facility's electrical infrastructure.
- 02. Electrical Distribution: Performed cable tray calculations to ensure a robust and code-compliant electrical distribution layout across the development's building network.
- 03. Building Safety Systems: Reviewed IFC drawings and supported installation of integrated safety systems — fire alarms, CO/heat sensors, CCTV, and access control — ensuring strict adherence to project specifications.
// Leadership_Roles
Outreach Lead & Electrical Engineer
Team Ojas Racing (Formula Student)
Engineered a Decentralized ECU & BMS Architecture
Moved away from a monolithic controller to a distributed network of CAN-connected nodes, significantly reducing wiring harness complexity and weight by placing acquisition modules closer to their signal sources. This architecture integrated a custom Master-Slave BMS to accommodate the battery stack configuration.
- 01. High-Voltage Integration: Architected the 600V system integration, implementing isoSPI for noise-immune battery monitoring (BMS) in an electrically noisy environment.
- 02. Safety & FMEA: Led Failure Mode and Effects Analysis (FMEA) to validate safety-critical logic, ensuring compliance with strict EV racing regulations.
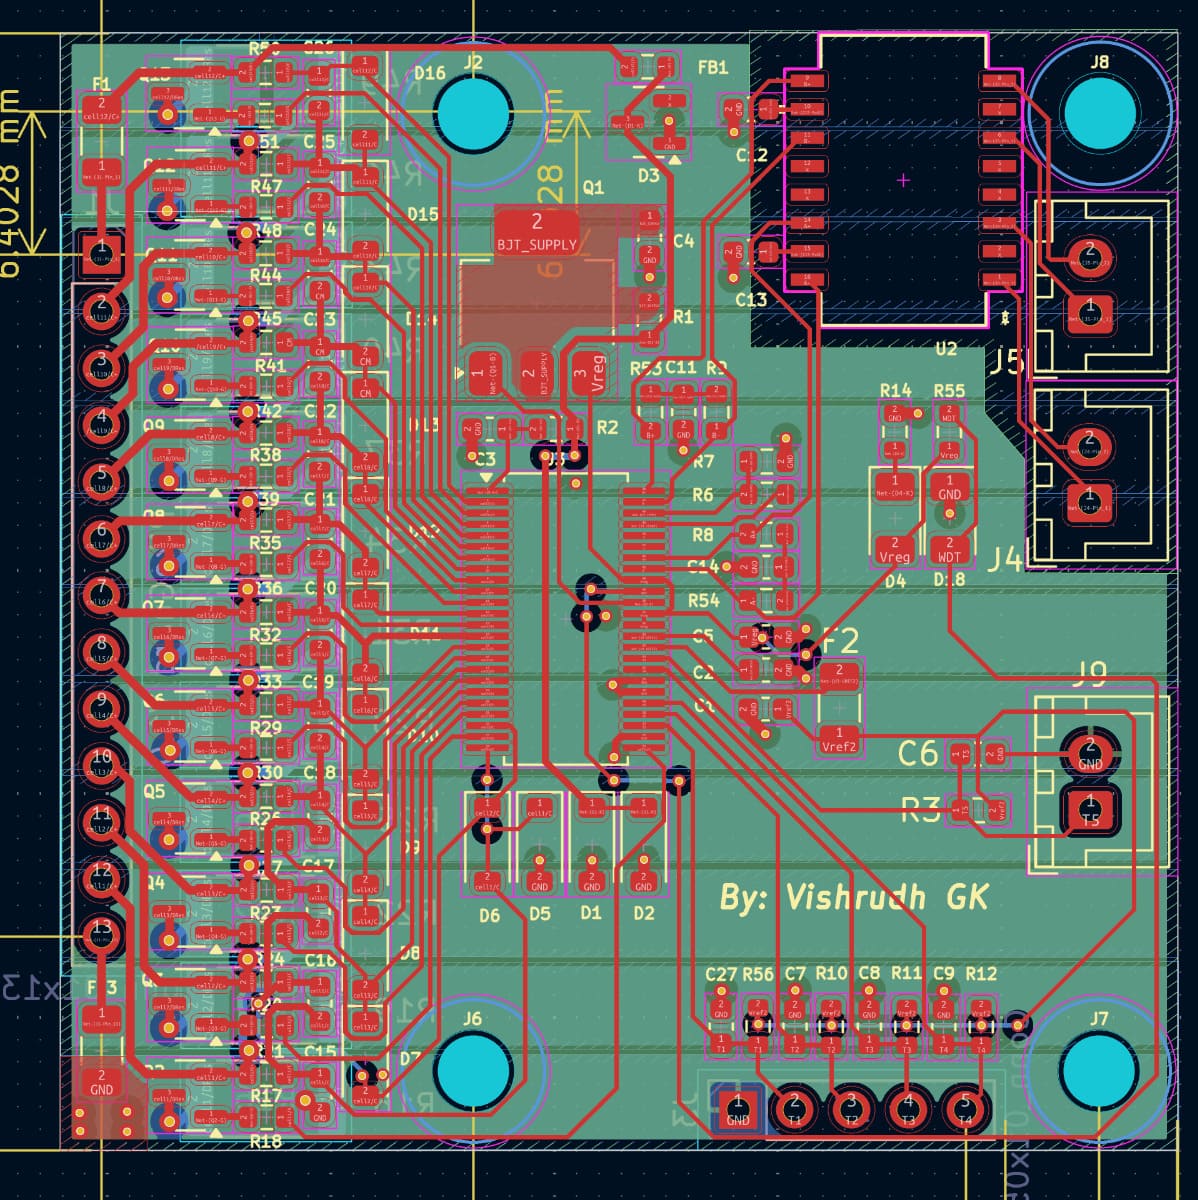
- 03. Review Process: Established a rigorous DFM/DFA review pipeline for schematics and PCB layouts, reducing hardware re-spins.
Design Head
Instrument Society of India (ISOI) — VIT Vellore
Led Visual Design for a Major Student Technical Chapter
Built and managed the chapter's visual identity — producing high-visibility creatives for some of VIT's largest events while mentoring the next generation of designers in Figma and Canva.
- 01. Event Creatives: Designed 25+ posters and promotional materials for flagship fests Riviera and Gravitas, displayed across major VIT venues to drive student engagement and event visibility.
- 02. Event Execution: Organized hackathons and technical events end-to-end — managing planning, faculty coordination, and on-ground execution to deliver consistent, well-run experiences.
- 03. Team Mentorship: Led and mentored a team of junior designers in Canva and Figma, standardizing design workflows and maintaining a consistent visual identity across all chapter communications.
.png)
.png)
 MATLAB
 Python
 Java
 C / C++
 C#
 KiCAD
 AutoCAD Electrical
 Fusion 360
 ROS / Gazebo
 Canva
 Figma
 MS Word
 Excel
 PowerPoint
 Outlook